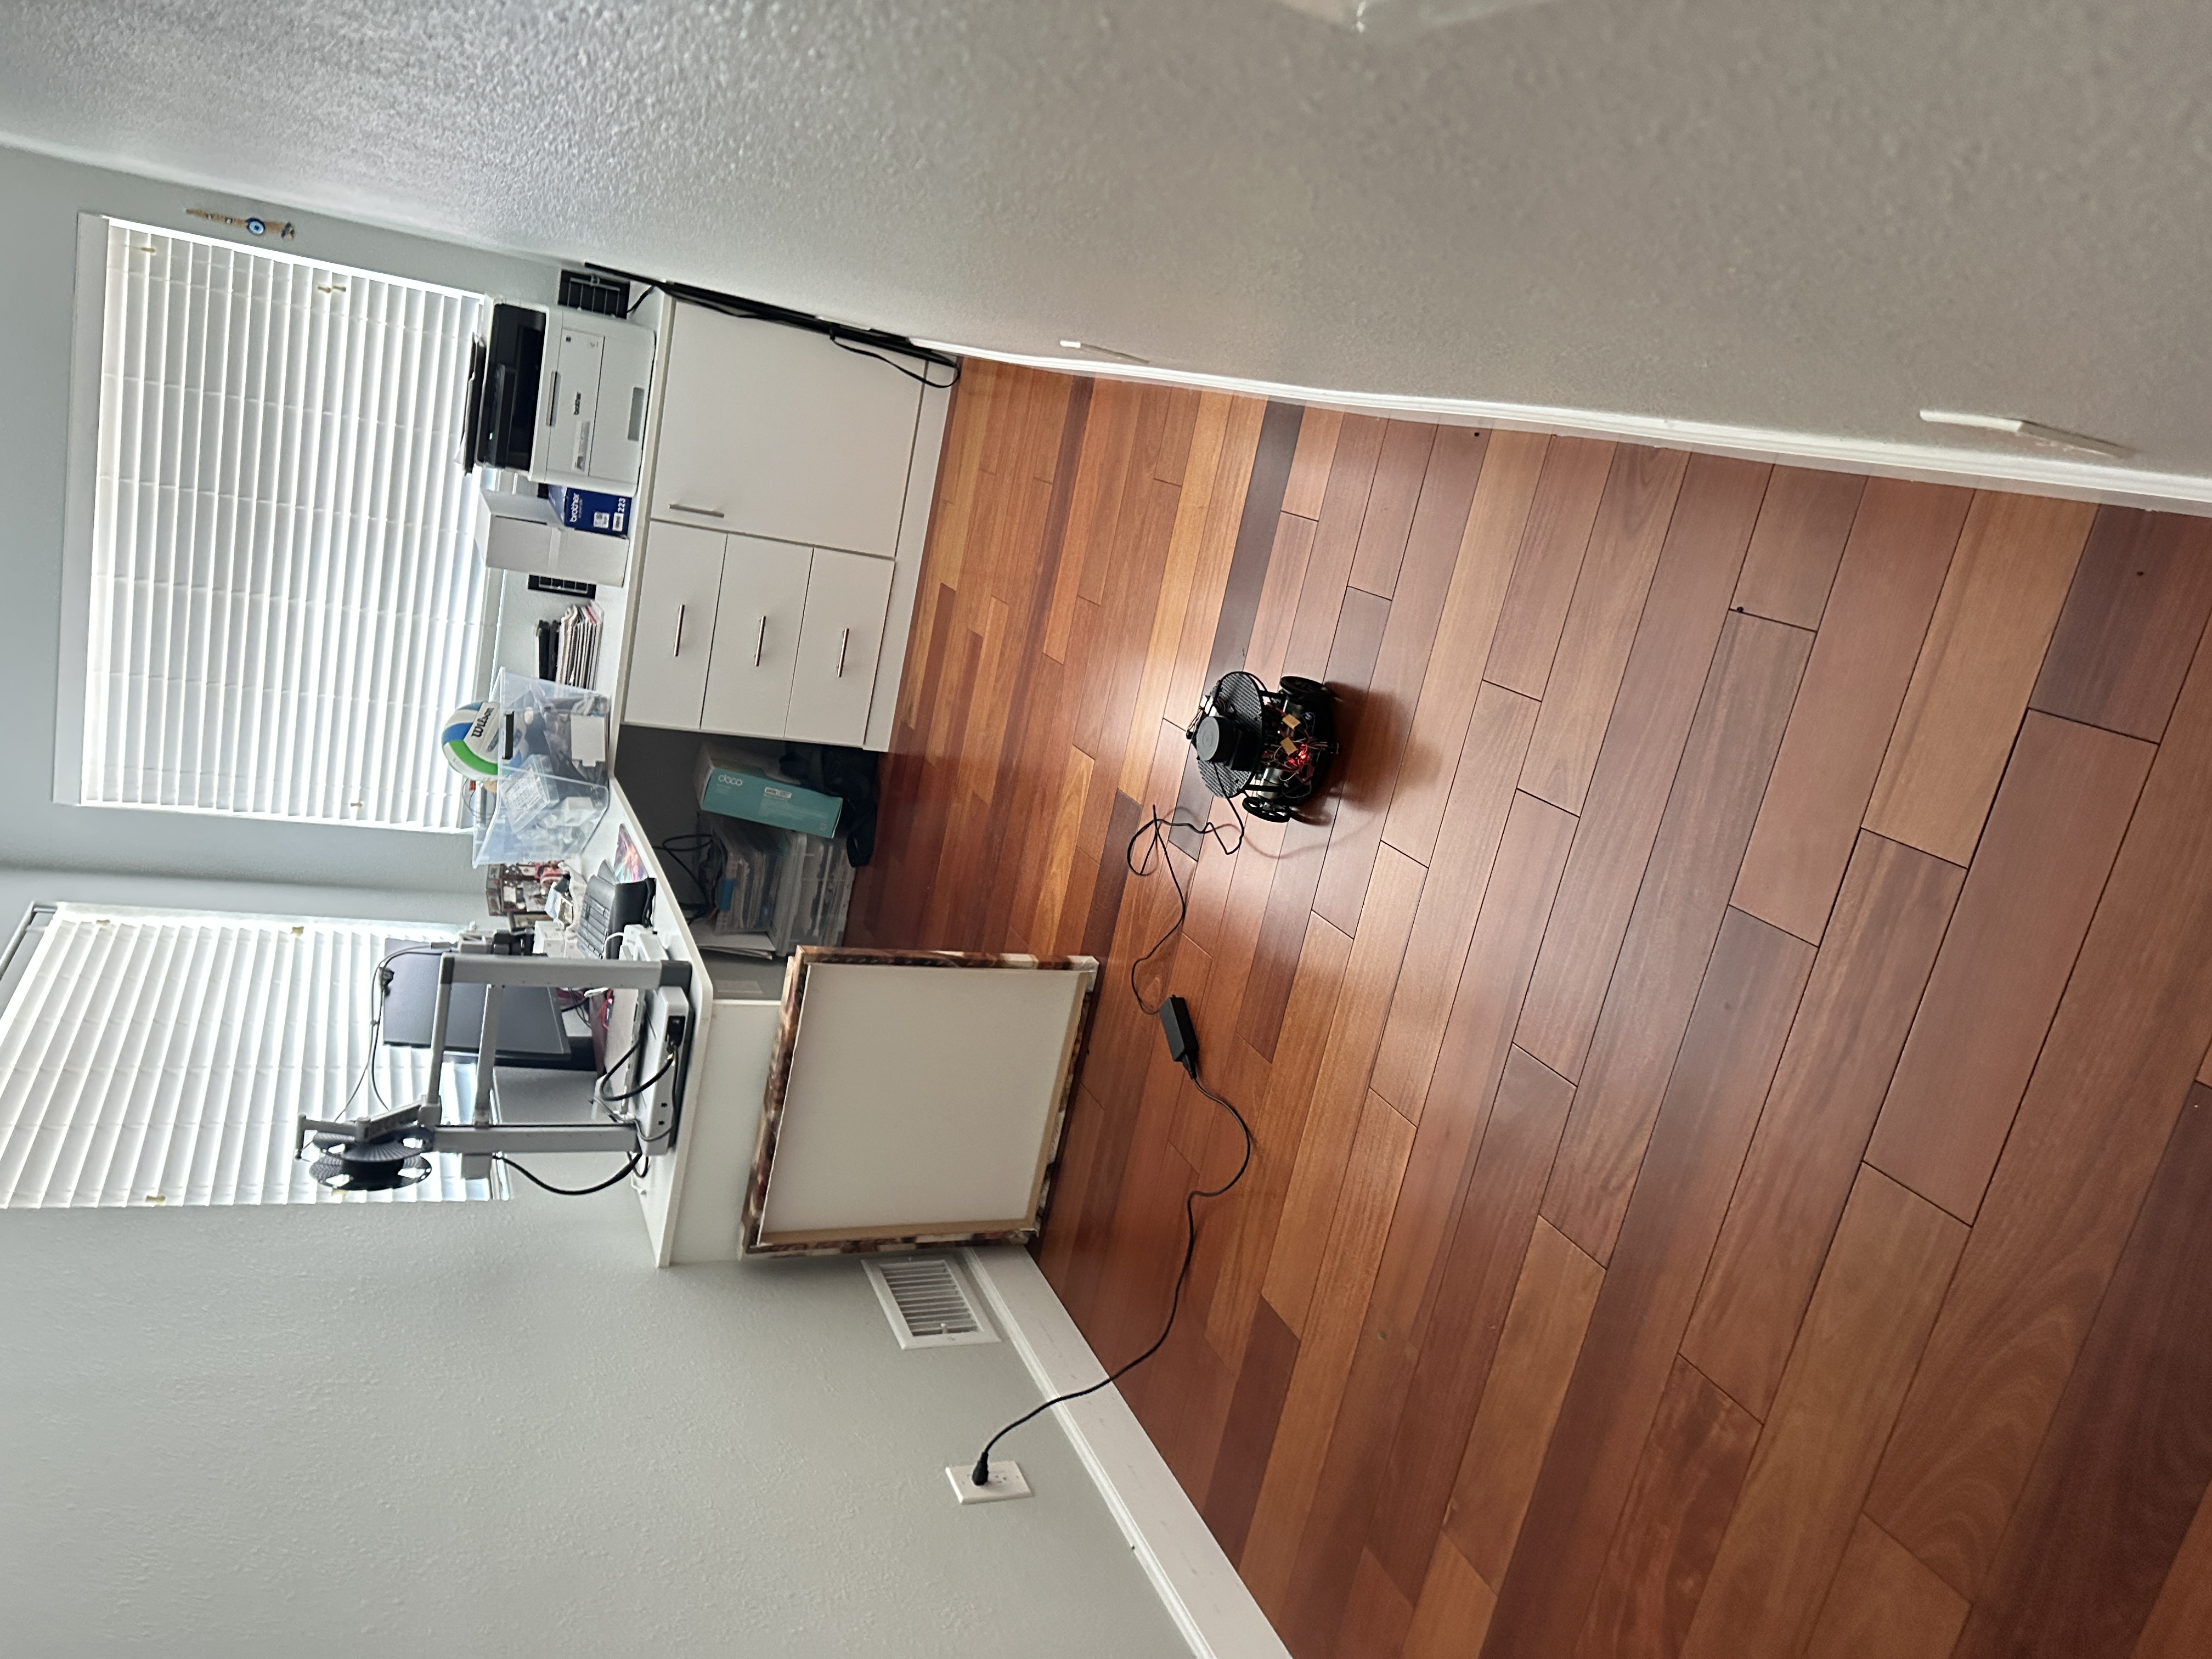
Autonomous indoor mapping robot
An indoor robot built from ESP32 wheel control through ROS 2 integration, LiDAR mapping, and Nav2 navigation. Demonstrated physical navigation uses a saved map and operator-selected goals; exploration work was tested offline.